NVIDIA-accelerated teleoperation solutions for robot data collection.
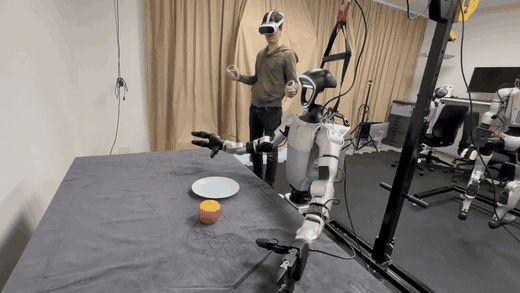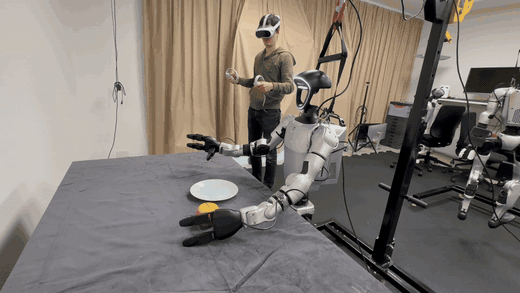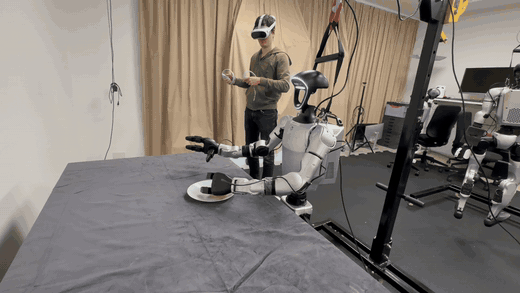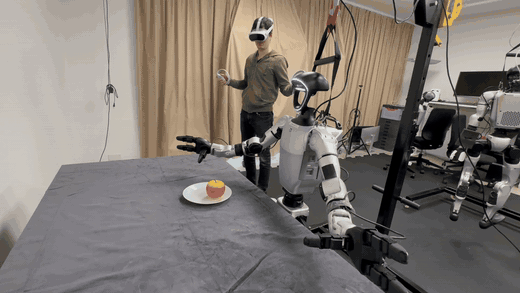
Isaac ROS Teleop contains a ROS 2 package for robot data collection.
isaac_ros_teleop relies on Isaac Teleop, a framework
for high-fidelity ego-centric and robot data collection. Isaac Teleop is designed to address the
data bottleneck in robot learning by streamlining device integration, allowing for high-fidelity human
demo data collection, and fosters device and data interoperability.
This repository is focused on using XR headsets for gripper or tri-finger hand manipulation using the PICO 4 Ultra or Meta Quest 3 headset.
Refer to the Isaac ROS Documentation to learn how to use this repository.
Update 2026-09-21: Publish end-effector poses as teleop_ros2_interfaces/NamedPoseArray instead of geometry_msgs/PoseArray, and add the pose_reset_config launch parameter that starts pose_reset_node